Team

The people behind Stringman and Neufangled Robotics.

About Neufangled Robotics

Neufangled Robotics is an open source hardware startup founded in North Carolina in 2025 by Nathaniel Nifong.

Our mission is to give people an organized home.

We prioritize robots that are narrowly effective at something that helps now rather than a general purpose robot that may be in devopment for years.

We put function over form. Our process is to identify an overlap between chores that need doing around the house, and things which a low cost robot can do, then design a system to do it, while making it as simple as possible for the end user.

We're not anti-humanoid robots, but we're *impatient*, so if there's something that could work today, we'd rather build that.

Nathaniel Nifong

Team members

Justin Kwarteng

Justin Kwarteng

Model evaluation and Teleop pilot

Drew Scott

Drew Scott

Manufacturing Engineer

Cheap robots get deployed and deployed robots get better.

LeRobot showed that lowering the barrier to entry to robotics is the way to build expertise and a large deployed base of hardware. But can any robot have enough reach and strength to do useful work while still keeping that cost barrier low enough for average people? We've chosen $1000 as that barrier. Roughly the cost of a dishwasher, and if any robot can be as useful as a dishwasher, then its a pretty good robot.

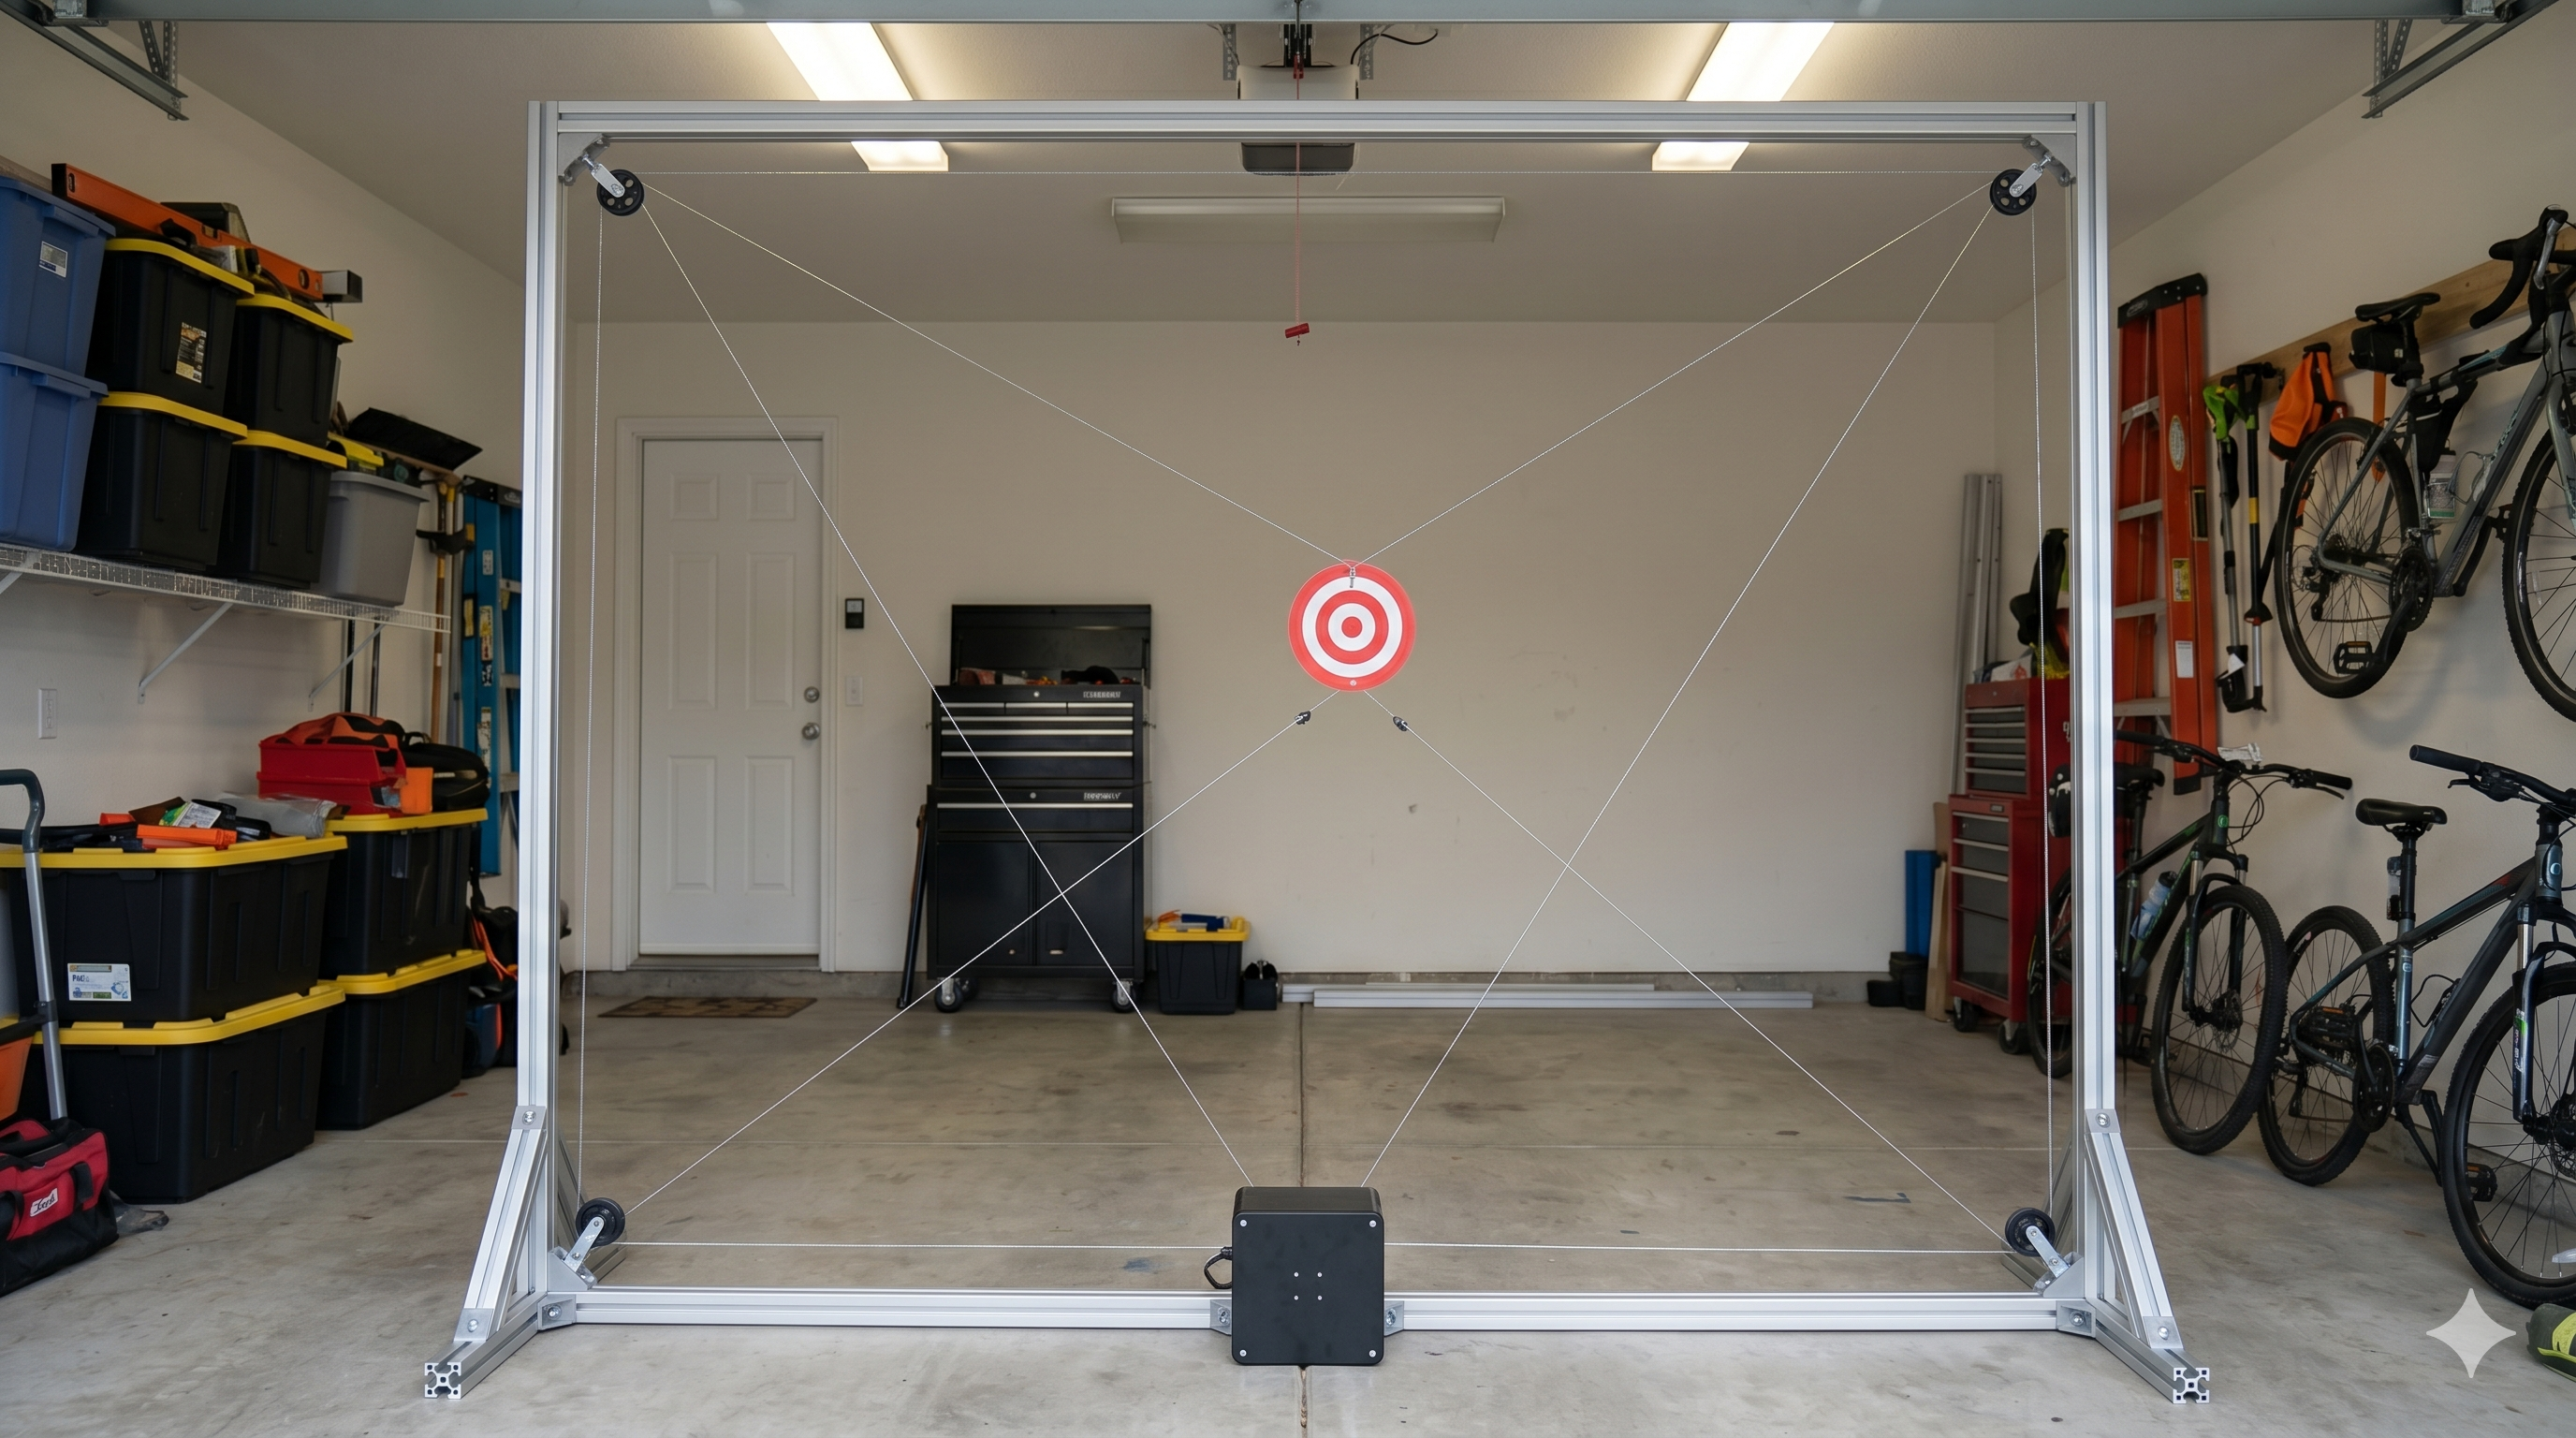
CDPRs have the potential to be in the small overlap between cheap and useful, so we're exploring the applications to see just what it's like to Live with an intelligent crane that moves your stuff around.

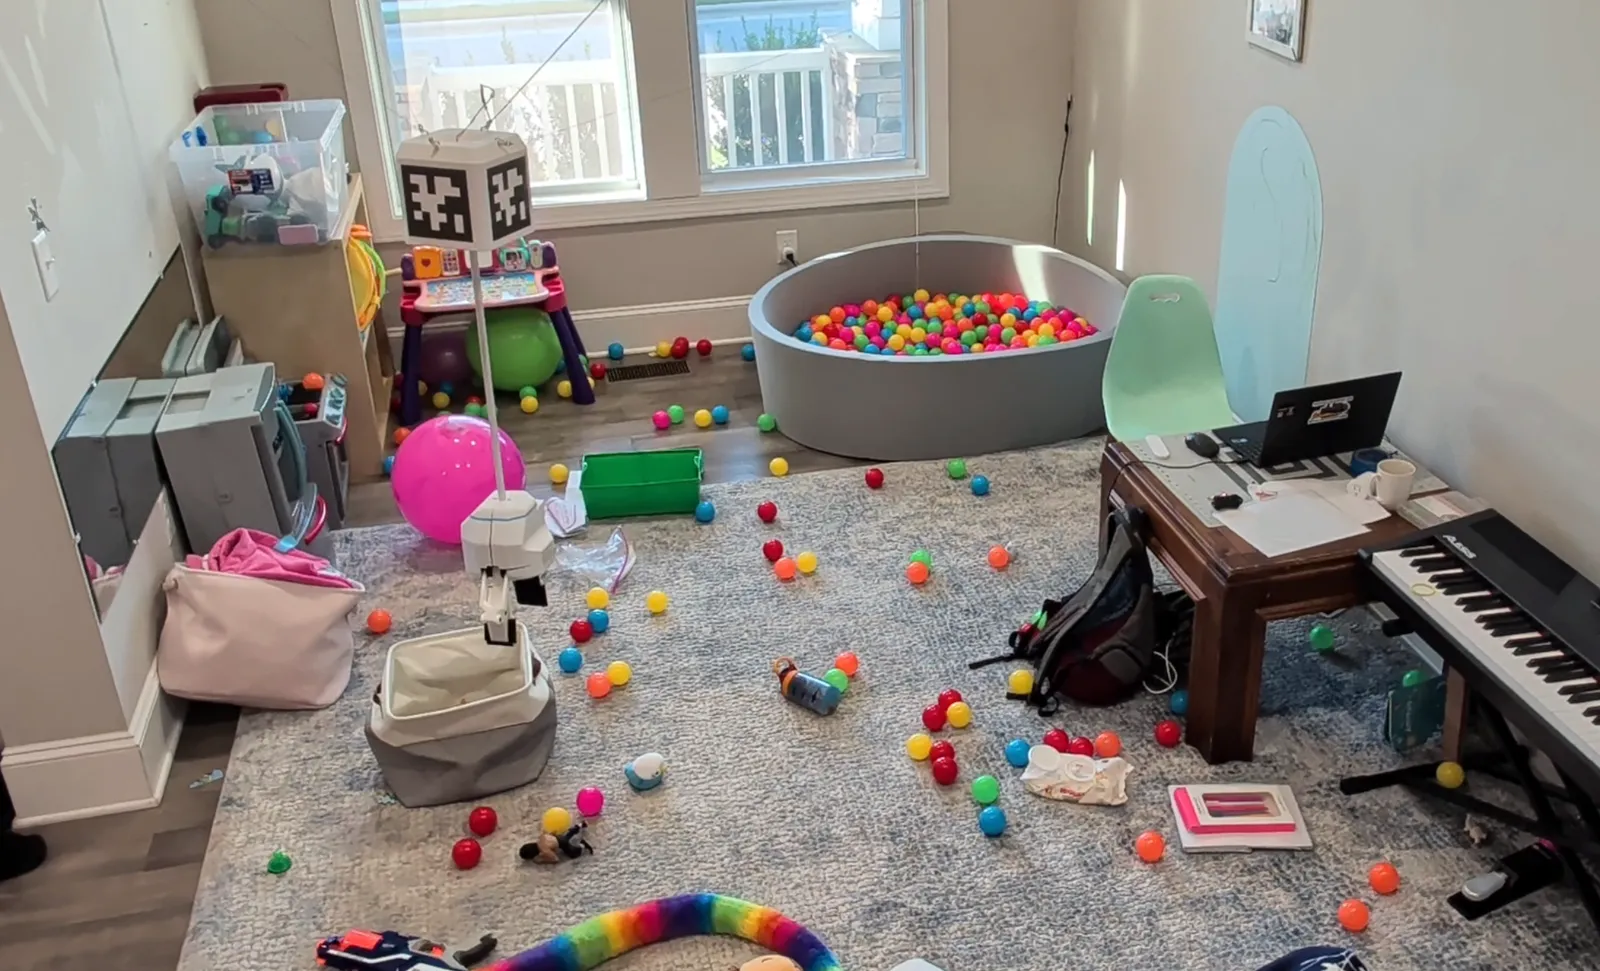
To date, our peak performance comes from the combination of a low level grasping model and MCP control by Claude or ChatGPT for orchestration. This setup can clean up most of the small items in a playroom in about an hour, putting things in most appropriate bins and leaving only objects that were too heavy to move such as furniture.

Stringman hanging in a messy room

The Long-Term Vision

We aim to be the most developed and well tested provider of cable robots in the United States.

  • Target practice device We are working on a self contained device that can move a target at about 0.6 m/s within a triangular plane srung between trees or buildings. The target would be able to perform evasive motions informed by a user-facing camera, or immitate the motion of various wild game.
  • Large scale Stringman Stringman's current room size is limited by the resolution of the camera during calibration. However there are many applications for a system for 50 meter rooms and 10kg payloads. If you have a space in which you think a system like this would be useful, please contact Nathaniel at the email below.

If these concepts interest you, or if you have features you'd desperately want to see in them, feel free to add your thoughts in the #ideas channel on Discord!

Hardware Updates

Built for Real Life

We dogfood our products — meaning we test them in our own homes with kids — to ensure that we're creating an end-to-end solution that is truly adapted to real life problems. Whether that means inconsistent lighting, ceiling fans or apple sauce, we are ready for it.

In my time as an engineer, one phrase comes back again and again - Untested code is broken

calibration cards on floor

Partnerships & Investing


naavox@gmail.com