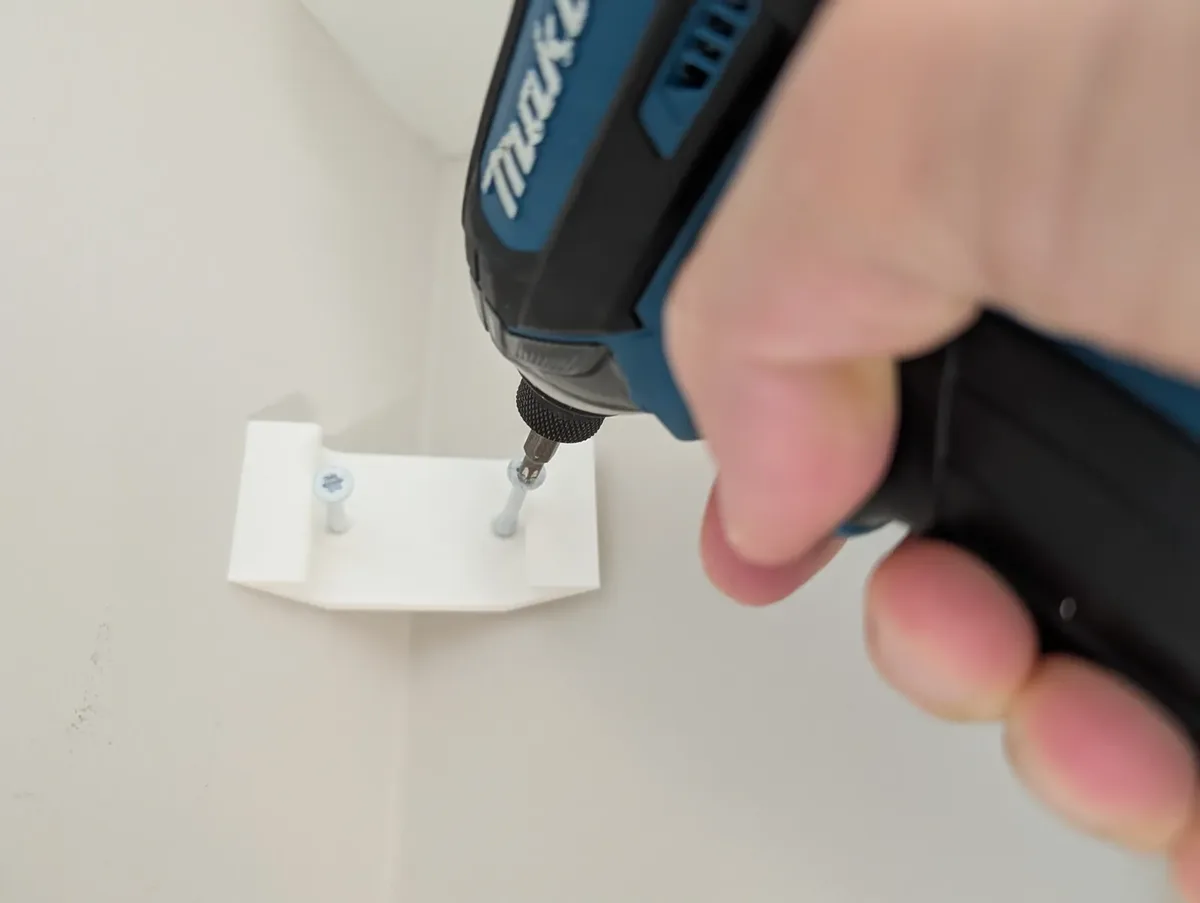
Secure the cleats to wall studs near the ceiling with wood screws, or to columns with ratchet straps.
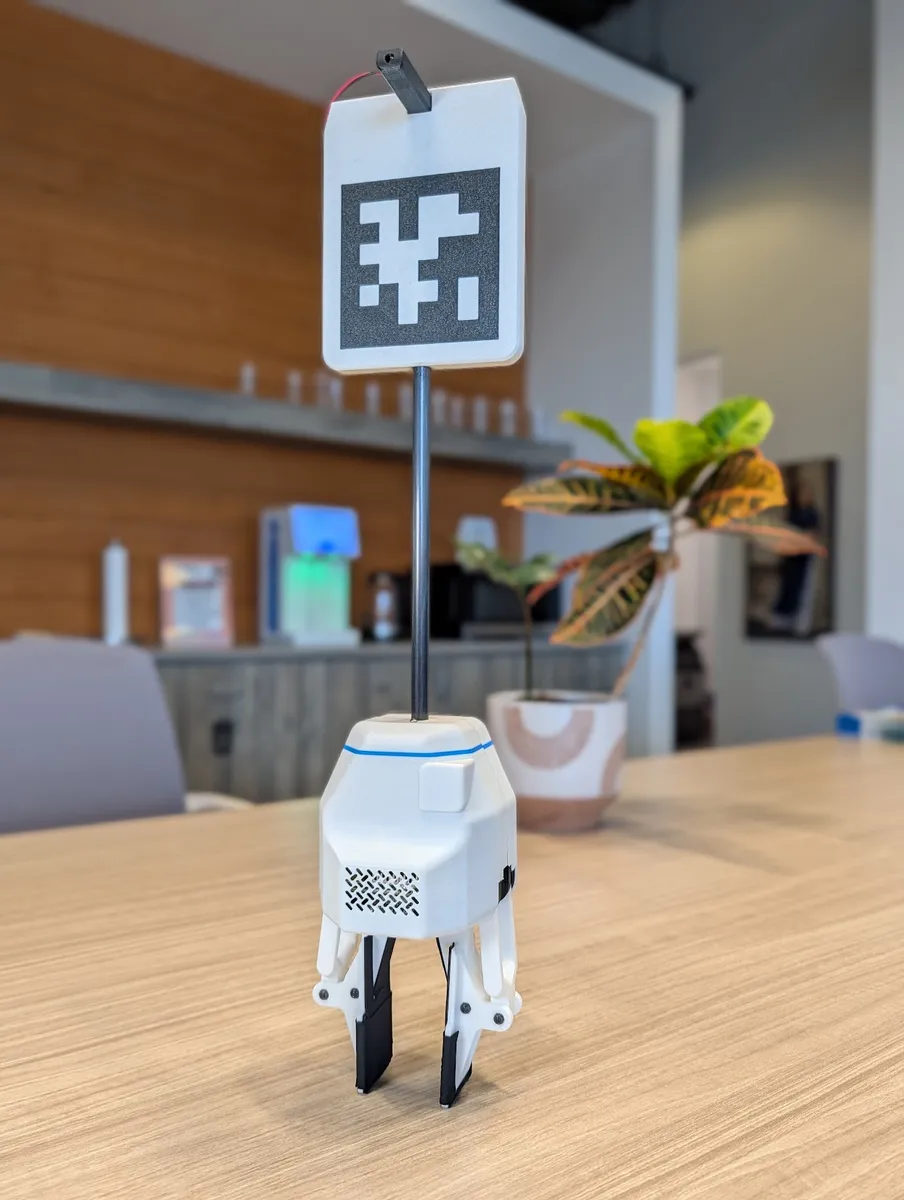
In robotics, price is basically actuator count. Stringman reaches an entire room with four motors, hanging its gripper from lines anchored in the ceiling corners. Working from above, it reaches floors too cluttered for any wheeled or legged robot. And since the lifting force is shared by all motors, payload capacity scales with their combined torque instead of a single actuator's, peaking near the center of the room where the lines share the load most evenly.
| Name | Actuator count | Average payload over work volume |
|---|---|---|
| Stringman | 4 | 1.25 kg |
| Typical arm* | 7 | 0.32 kg |
*0.75 m serial arm using the same DM-H6215 1 N·m direct drive actuators at rated torque, ignoring the weight of its own links. Stringman figure is for a 7 × 7 × 3 m room.
| Work area | Room sizes between 2m and 10m (XY diagonal). Room heights between 2m and 4m |
|---|---|
| Payload | Up to 2 kg near the floor, 1.25kg on average. |
| Traverse speed | ~0.4 m/s |
| Cameras | 2 anchor cameras @ 1920x1080 30fps and 1 wide FOV gripper camera @ 684x384 60fps |
| Compute | External. (Your PC as controller) Raspberry Pi Zero 2W (gripper) and Pi 3A+ (anchors). |
| Connectivity | 5 GHz Wi-Fi using QR-codes for simple setup. (gripper 2.4 Ghz only) |
| Materials | 3D printed. Structural parts: PET-GF, Decorative parts: PLA |
| Mounting options | Wooden stud backed drywall or plaster wall mounts. Strapping to structural columns. |
| Endurance | ~1000h of testing in real homes accumulated so far. |
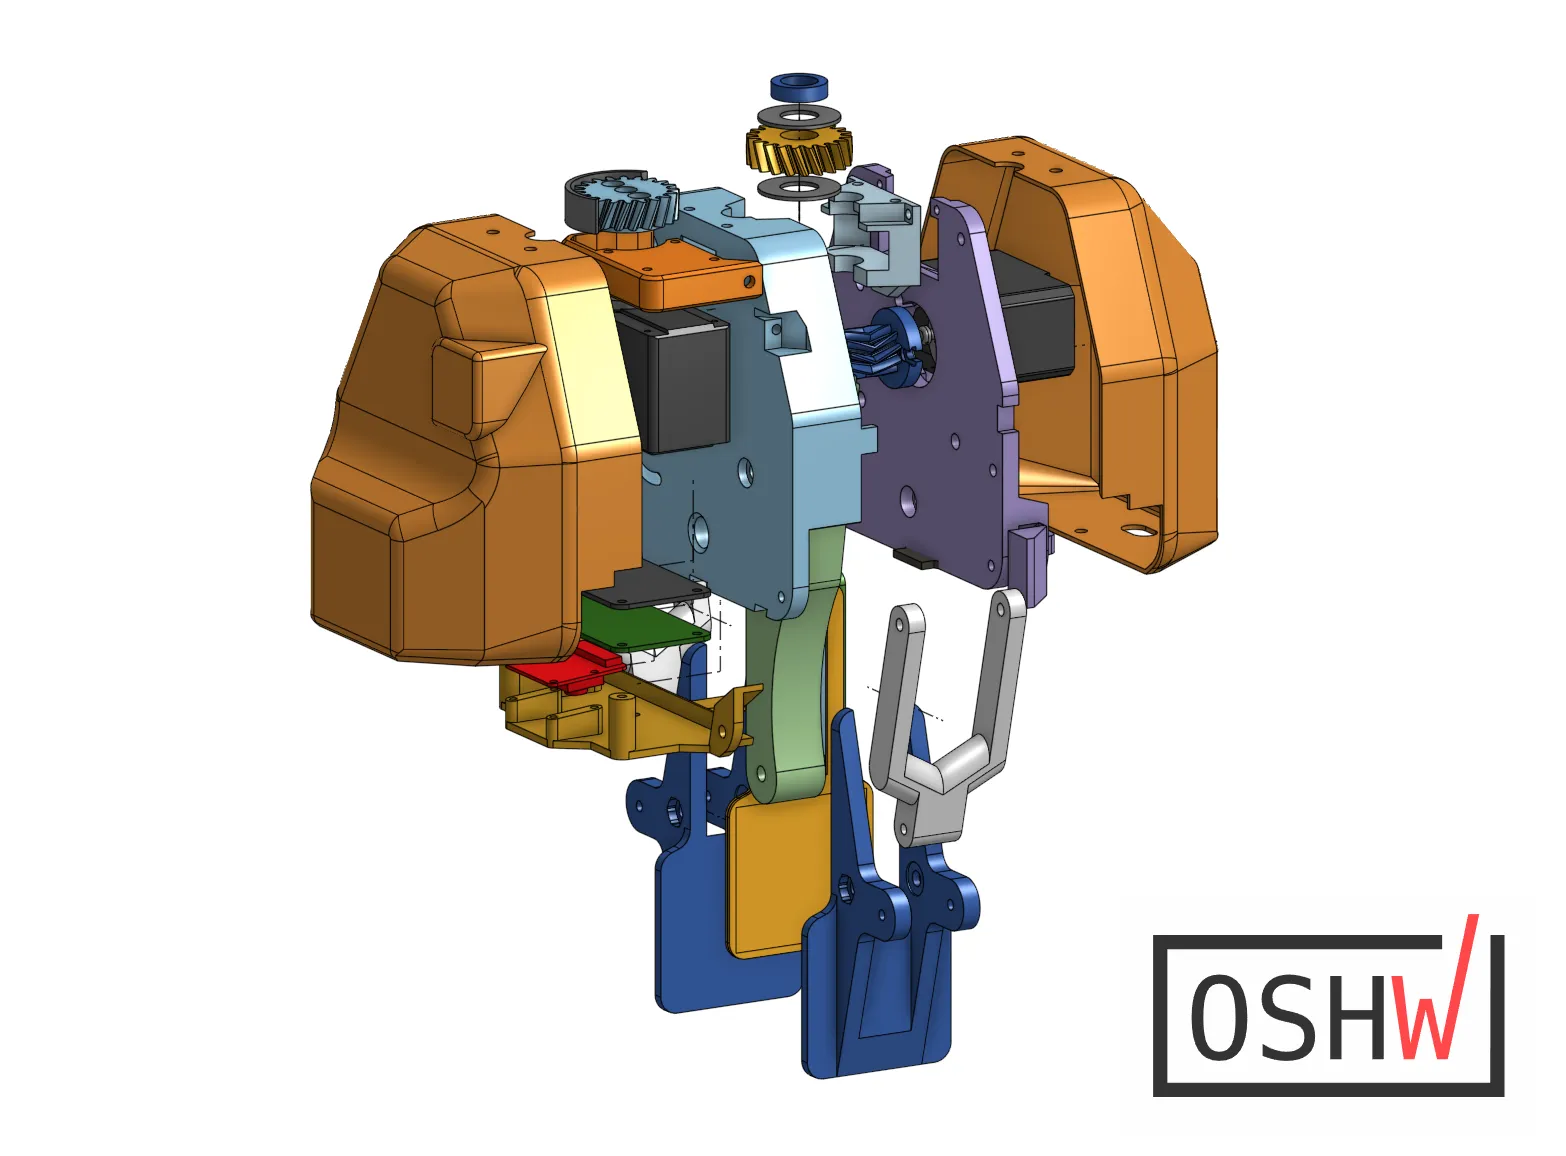
Stringman is open source and OSHWA certified. The mechanical CAD, the PCBs, and the control software are all published.
We believe owners should be in control of their own robots. That's why Stringman can run air gapped on your local Wi-Fi network: the UI is served locally, AI models run on your own hardware, and no data ever leaves your network.
Give your home lab the capability of carrying parts from one workcell to another anywhere in the room, so you can get more out of your other robots. The Python API and MCP server is made for agents so you can get your workflow running right away.
2022 Porsche 911 GT3 RSR model by No Limits, CC BY 4.0, simplified. SO-101 arm from TheRobotStudio/SO-ARM100, Apache 2.0.
Unlike desktop arms limited to a fixed radius, Stringman leverages a cable-driven architecture to access the full volume of a room. The work area volume per dollar of this type of robot is completely unmatched, all with fewer actuators than even the simplest mobile robots. Anchors and eylets are mounted in the corners of the room near the ceiling and define a four-sided work area within which any object can be moved from point to point.
| Stringman | Research arm | |
|---|---|---|
| Work area | 7 × 7 × 3 m room (147 m³) |
0.75 m hemisphere (0.88 m³) |
| Price | $795 | $2,500 |
| Volume per $1,000 | 185 m³ | 0.35 m³ |
That's roughly 500× the work area volume per dollar, at comparable 2 kg payload.
Secure the cleats to wall studs near the ceiling with wood screws, or to columns with ratchet straps.
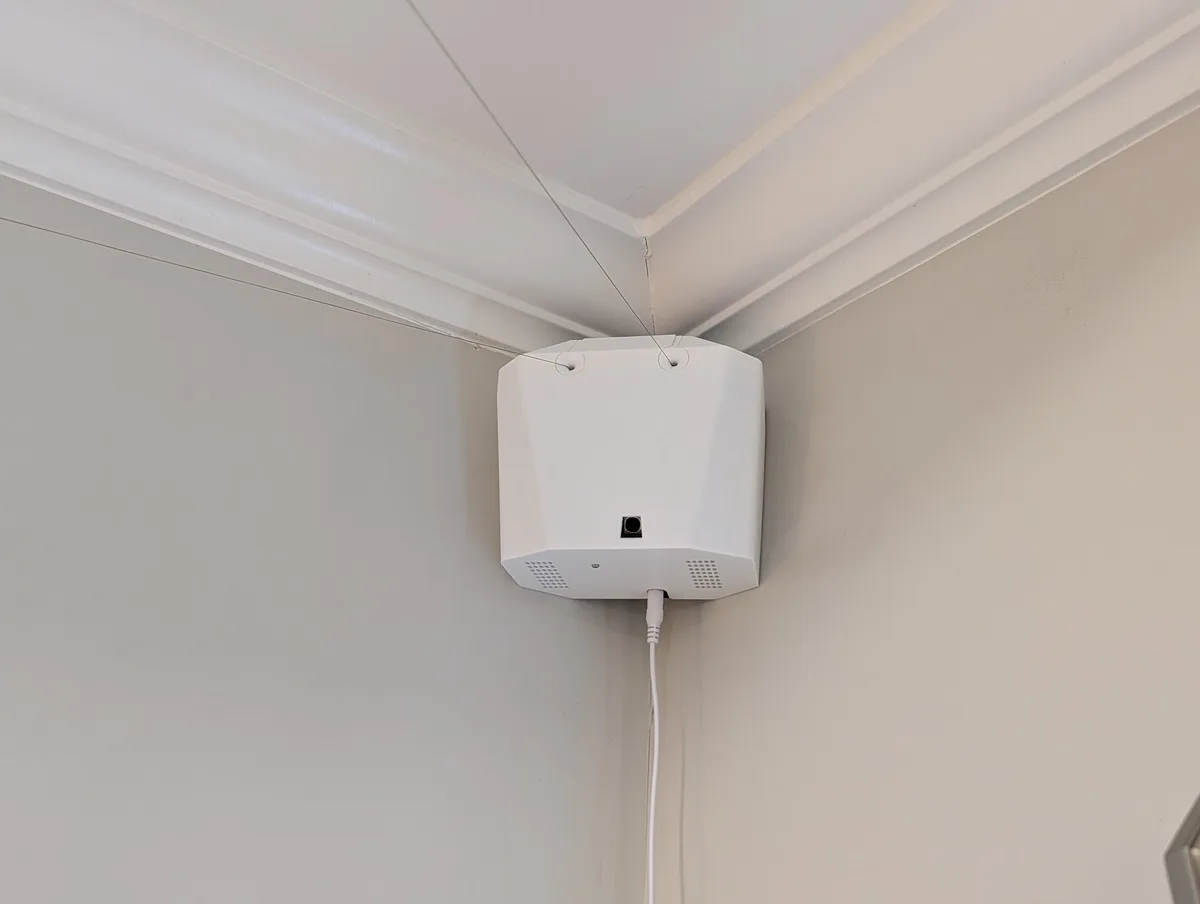
Hang the anchors and connect the lines to the gripper.
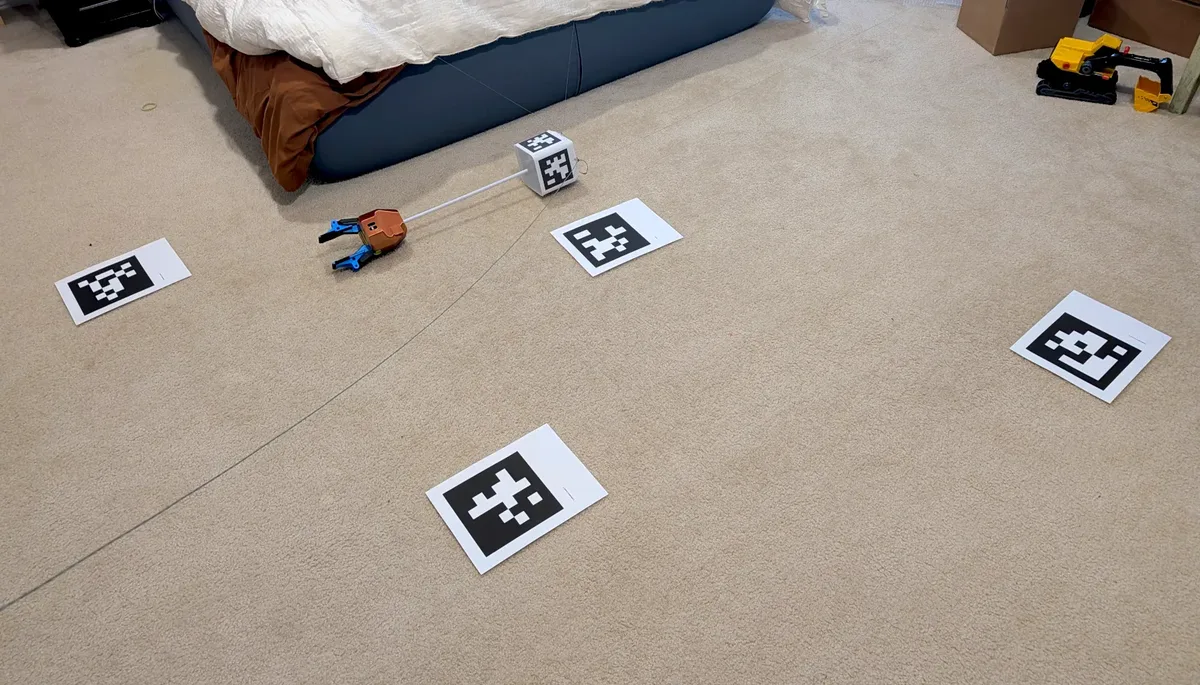
Run calibration. This hands off process takes about five minutes and adapts Stringman to your room.
Step-by-step: picture guide or video guide
The original prototype was built in a room with a ceiling fan, and it still runs there today. Mount the anchors at or below the level of the blades and the lines can't physically reach it.
Several methods are available for control with default models for automatic grasping, target, and destination selection to make it easy to quickly build new behaviors.
Stringman is fully capable of LeRobot control using including Pi.05, JEPA, Multitask DiT, and others.
Collecting training data for new behaviors can be done from the UI, and as few as 50 episodes can be enough for certain models like DiT to learn a behavior.
As long as it remains installed, yes. However, when parked, they are up near the ceiling and out of the way. Clutter on the ceiling is preferable to clutter on the floor in our opinion. If you need to remove the anchors, they can be detached from their mounts without tools, leaving a relatively small white cleat on the wall.
Yes, it's just a matter of mounting the anchors at or below the level of the fan, making it physically impossible for the lines or marker tag to touch it. Similarly, the work area can be shrunk to exclude low hanging light fixtures if they are off to the side, but if the center of the room does contain low hanging objects, Stringman cannot be installed in that room.
When reaching a tension limit of 28 newtons (about the weight of a backpack), all motors relax and the lines can be pulled loose. Since they are overhead most of the time, it's uncommon for people to collide with them.
Not by default, but if you bind it with neufangled.com/playroom then you or anyone you share access with can operate it from anywhere, and access can be revoked at any time. Neufangled Robotics does not store any of the information from your robot that is forwarded through its servers.
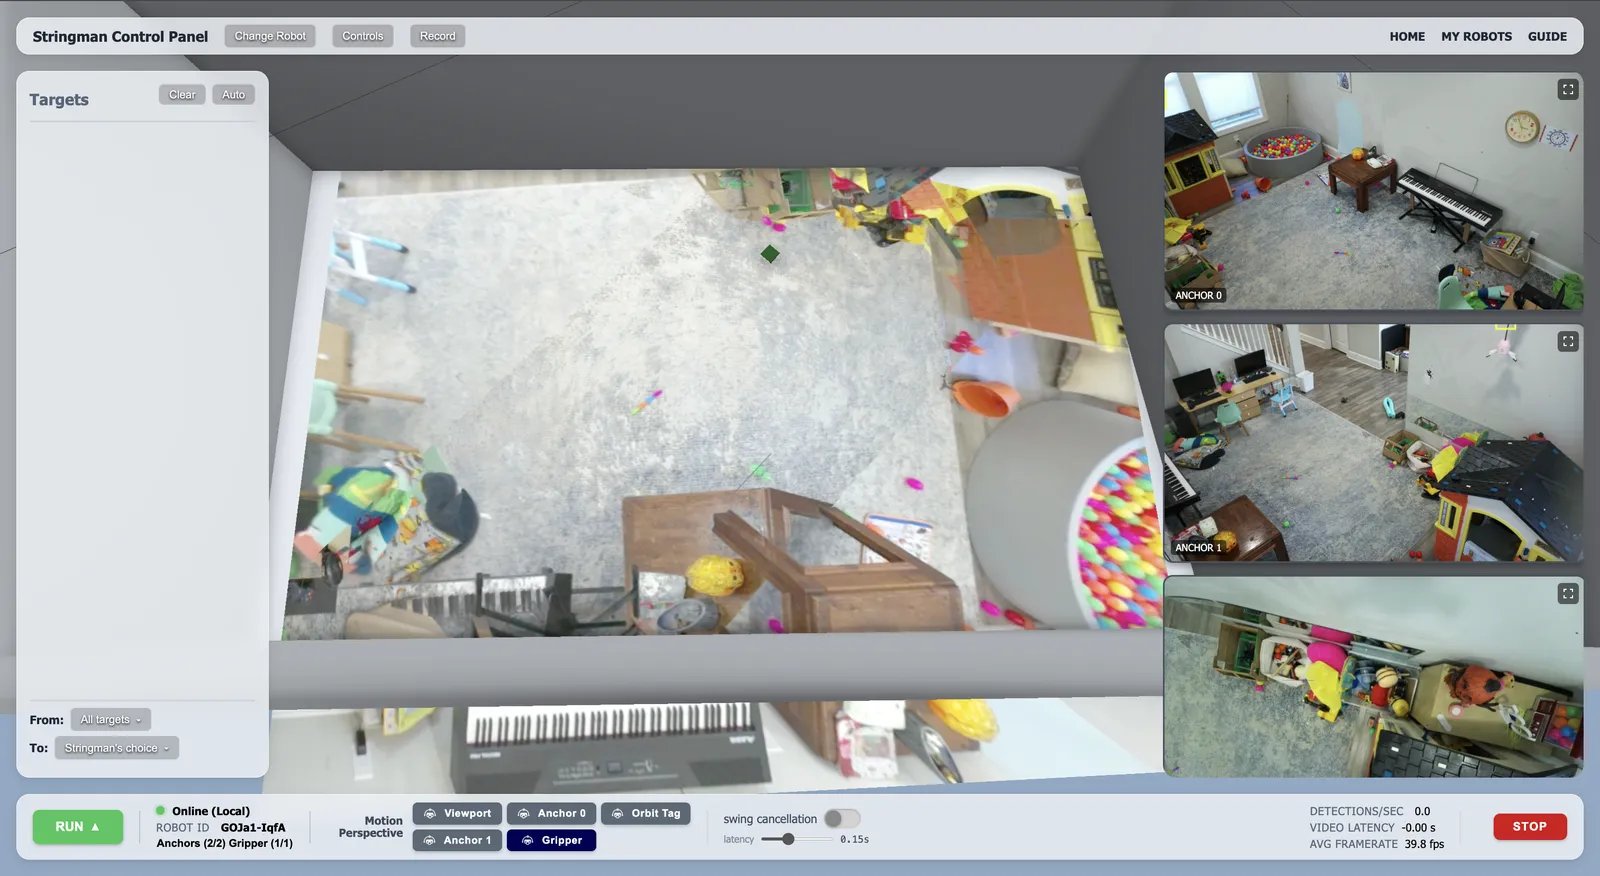
For those who prefer to make the trade-off by binding their robot to an account, our web-based console allows you to monitor and control Stringman from anywhere. Think of it as a security camera with a hand.
If you do decide that you would like to make use of our cloud telemetry relay, You can use it, and still go back to a completely lan only mode whenever you want. Your data is never collected.
Organizing your home is a physical process, not a coding task. Use our clip-on fiducial tags to designate your laundry bin, toy box, and trash can. Stringman maps these locations visually. You don't need to tag individual pieces of clutter—just the destination. If there's something you never want it to pick up, you can mark that item as off-limits.
Networks trained to control stringman have learned that the word "toybox" refers to that tag, so you can use it to mark anything even if it doesn't look like the toyboxes from our training set.
You can also use the tags as arbitrary source and destination markers for ferry jobs, such as carrying items from one robot arm to another. or carrying laundry from the ground to a robotic folding station
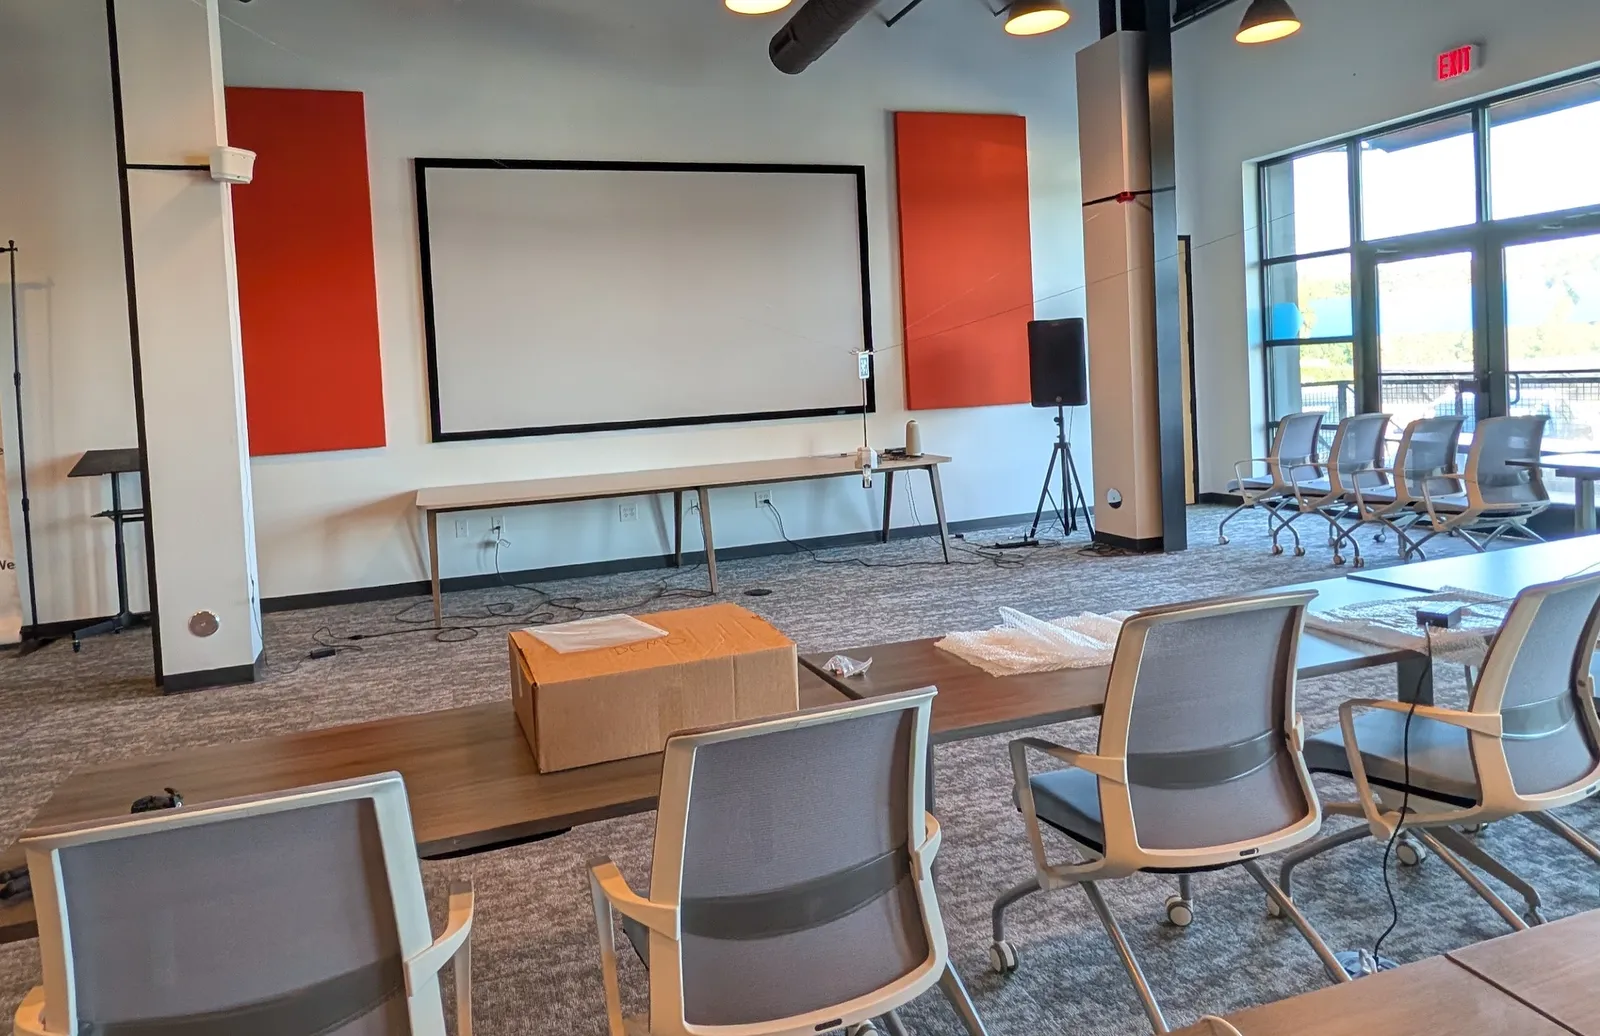
A classroom with a Stringman robot gives your students a chance to become familiar with robotics fundamentals such as inverse kinematics, telemetry, and imitation learning while controlling an exotic and capable flying gripper. If you have walls and a MacBook, you're more than halfway there.
Cross embodiment is one of the biggest challenges in robotics, and showing that a model can operate a vastly different body type is a stronger result than moving it from one bimanual robot to another. Our datasets are public on Hugging Face, there's a controller-in-the-loop MuJoCo sim, and Stringman works with LeRobot, making it one of the most inexpensive robots to test on and a natural capstone project.
Mobile robots spend a significant portion of their time charging. Because Stringman is a powered from the wall, it's always ready for work. Furthermore, by removing the heavy battery pack, we've increased the payload capacity per dollar compared to mobile platforms that must waste energy carrying their own power supply.
The gripper's power is delivered via one of the support cables. A two-conductor FEP jacketed twisted pair cable with a tensile strength of 50N.
What's that pole for? Stringman's gripper hangs below the pivot point so it can reach the floor next to beds and tables. This additional linkage could allow unconstrained motion so Stringman employs active swing cancellation algorithms to counteract momentum, without adding the cost of any additional motors. This ensures the gripper remains steady and predictable even during rapid cross-room traversals.
There's a whole video about swing cancellation if you're curious about how it works!
Often, a simple solution that gets the job done has more value than a complex one. Stringman uses a two fingered gripper with a wrist. This is enough dexterity for the clutter it is designed to pick up, keeping weight and cost low and reliability high. In our household tests we have determined that more layers of grip tape is simply a better return on investment than more articulated fingers.
The gripper can rotate it's wrist to better place the fingers around flat sided or long objects.
For a easy preview of how it looks in your room, print the anchor mockup in white PLA and hold it up in a corner. Get the files.
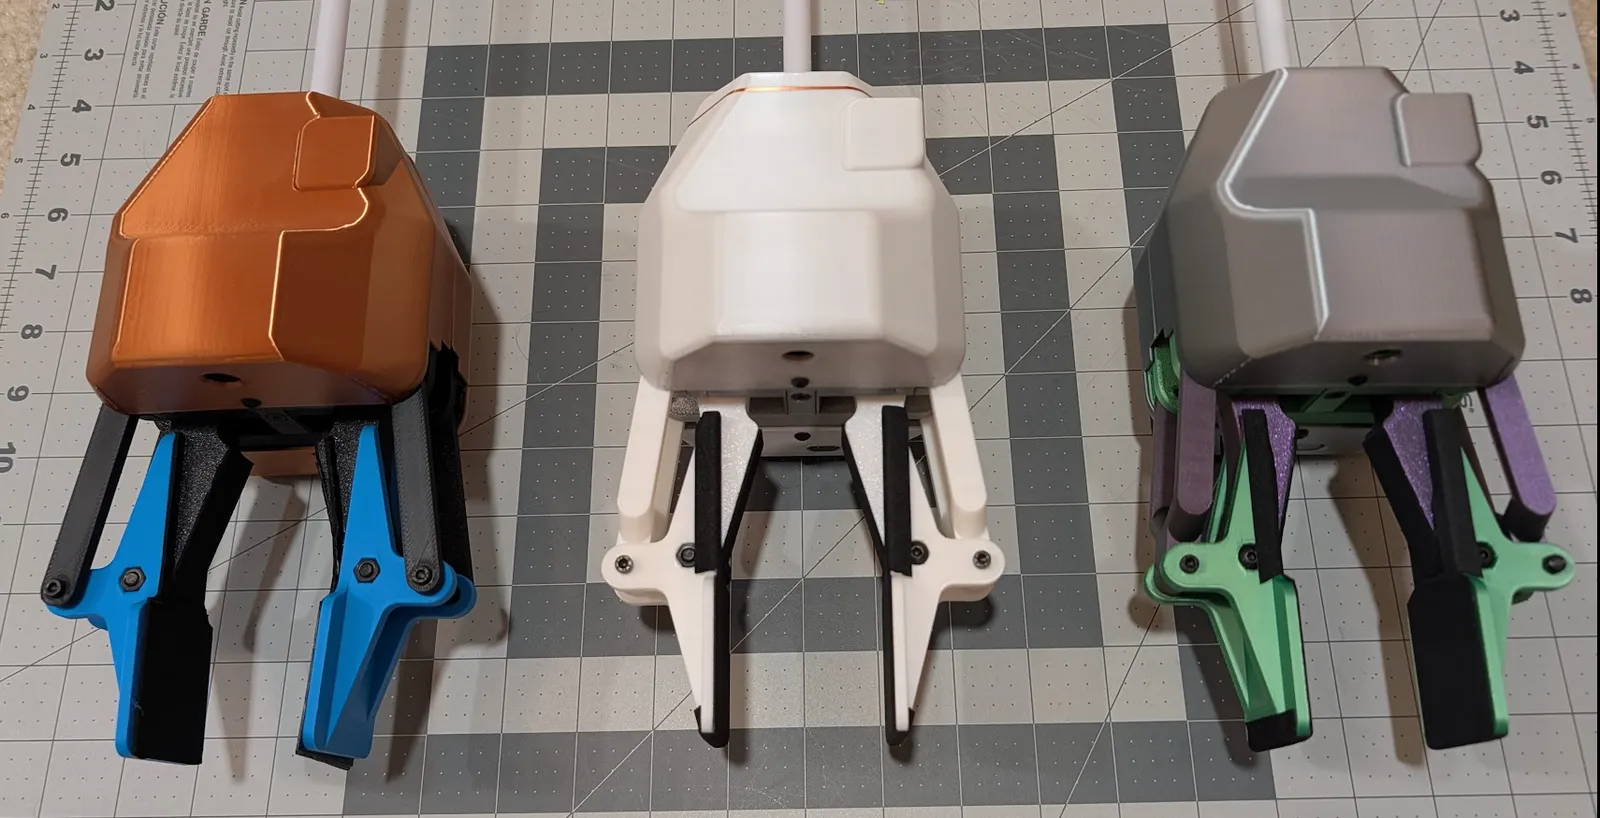
TThe Stringman faceplate is easily swappable. Grab the STL or bambu 3MF files to print your faceplate in any color.
Join our community for support, live updates, and direct chat with the developer.
Join ServerSubscribe for major product announcements, software updates, and new hardware releases.
SubscribeWatch full demonstrations, tutorials, and deep-dives into Stringman's kinematics and build processes.
Watch VideosExplore the open-source firmware, contribute to the codebase, and report technical issues.
View Code